WRO Future Engineers 2026 — Autonomous Vehicle
An autonomous vehicle built with Team Traktoristak for the World Robot Olympiad (WRO) Future Engineers 2026 category. I led the project — developing the software and hardware, and leading the mechanical design.
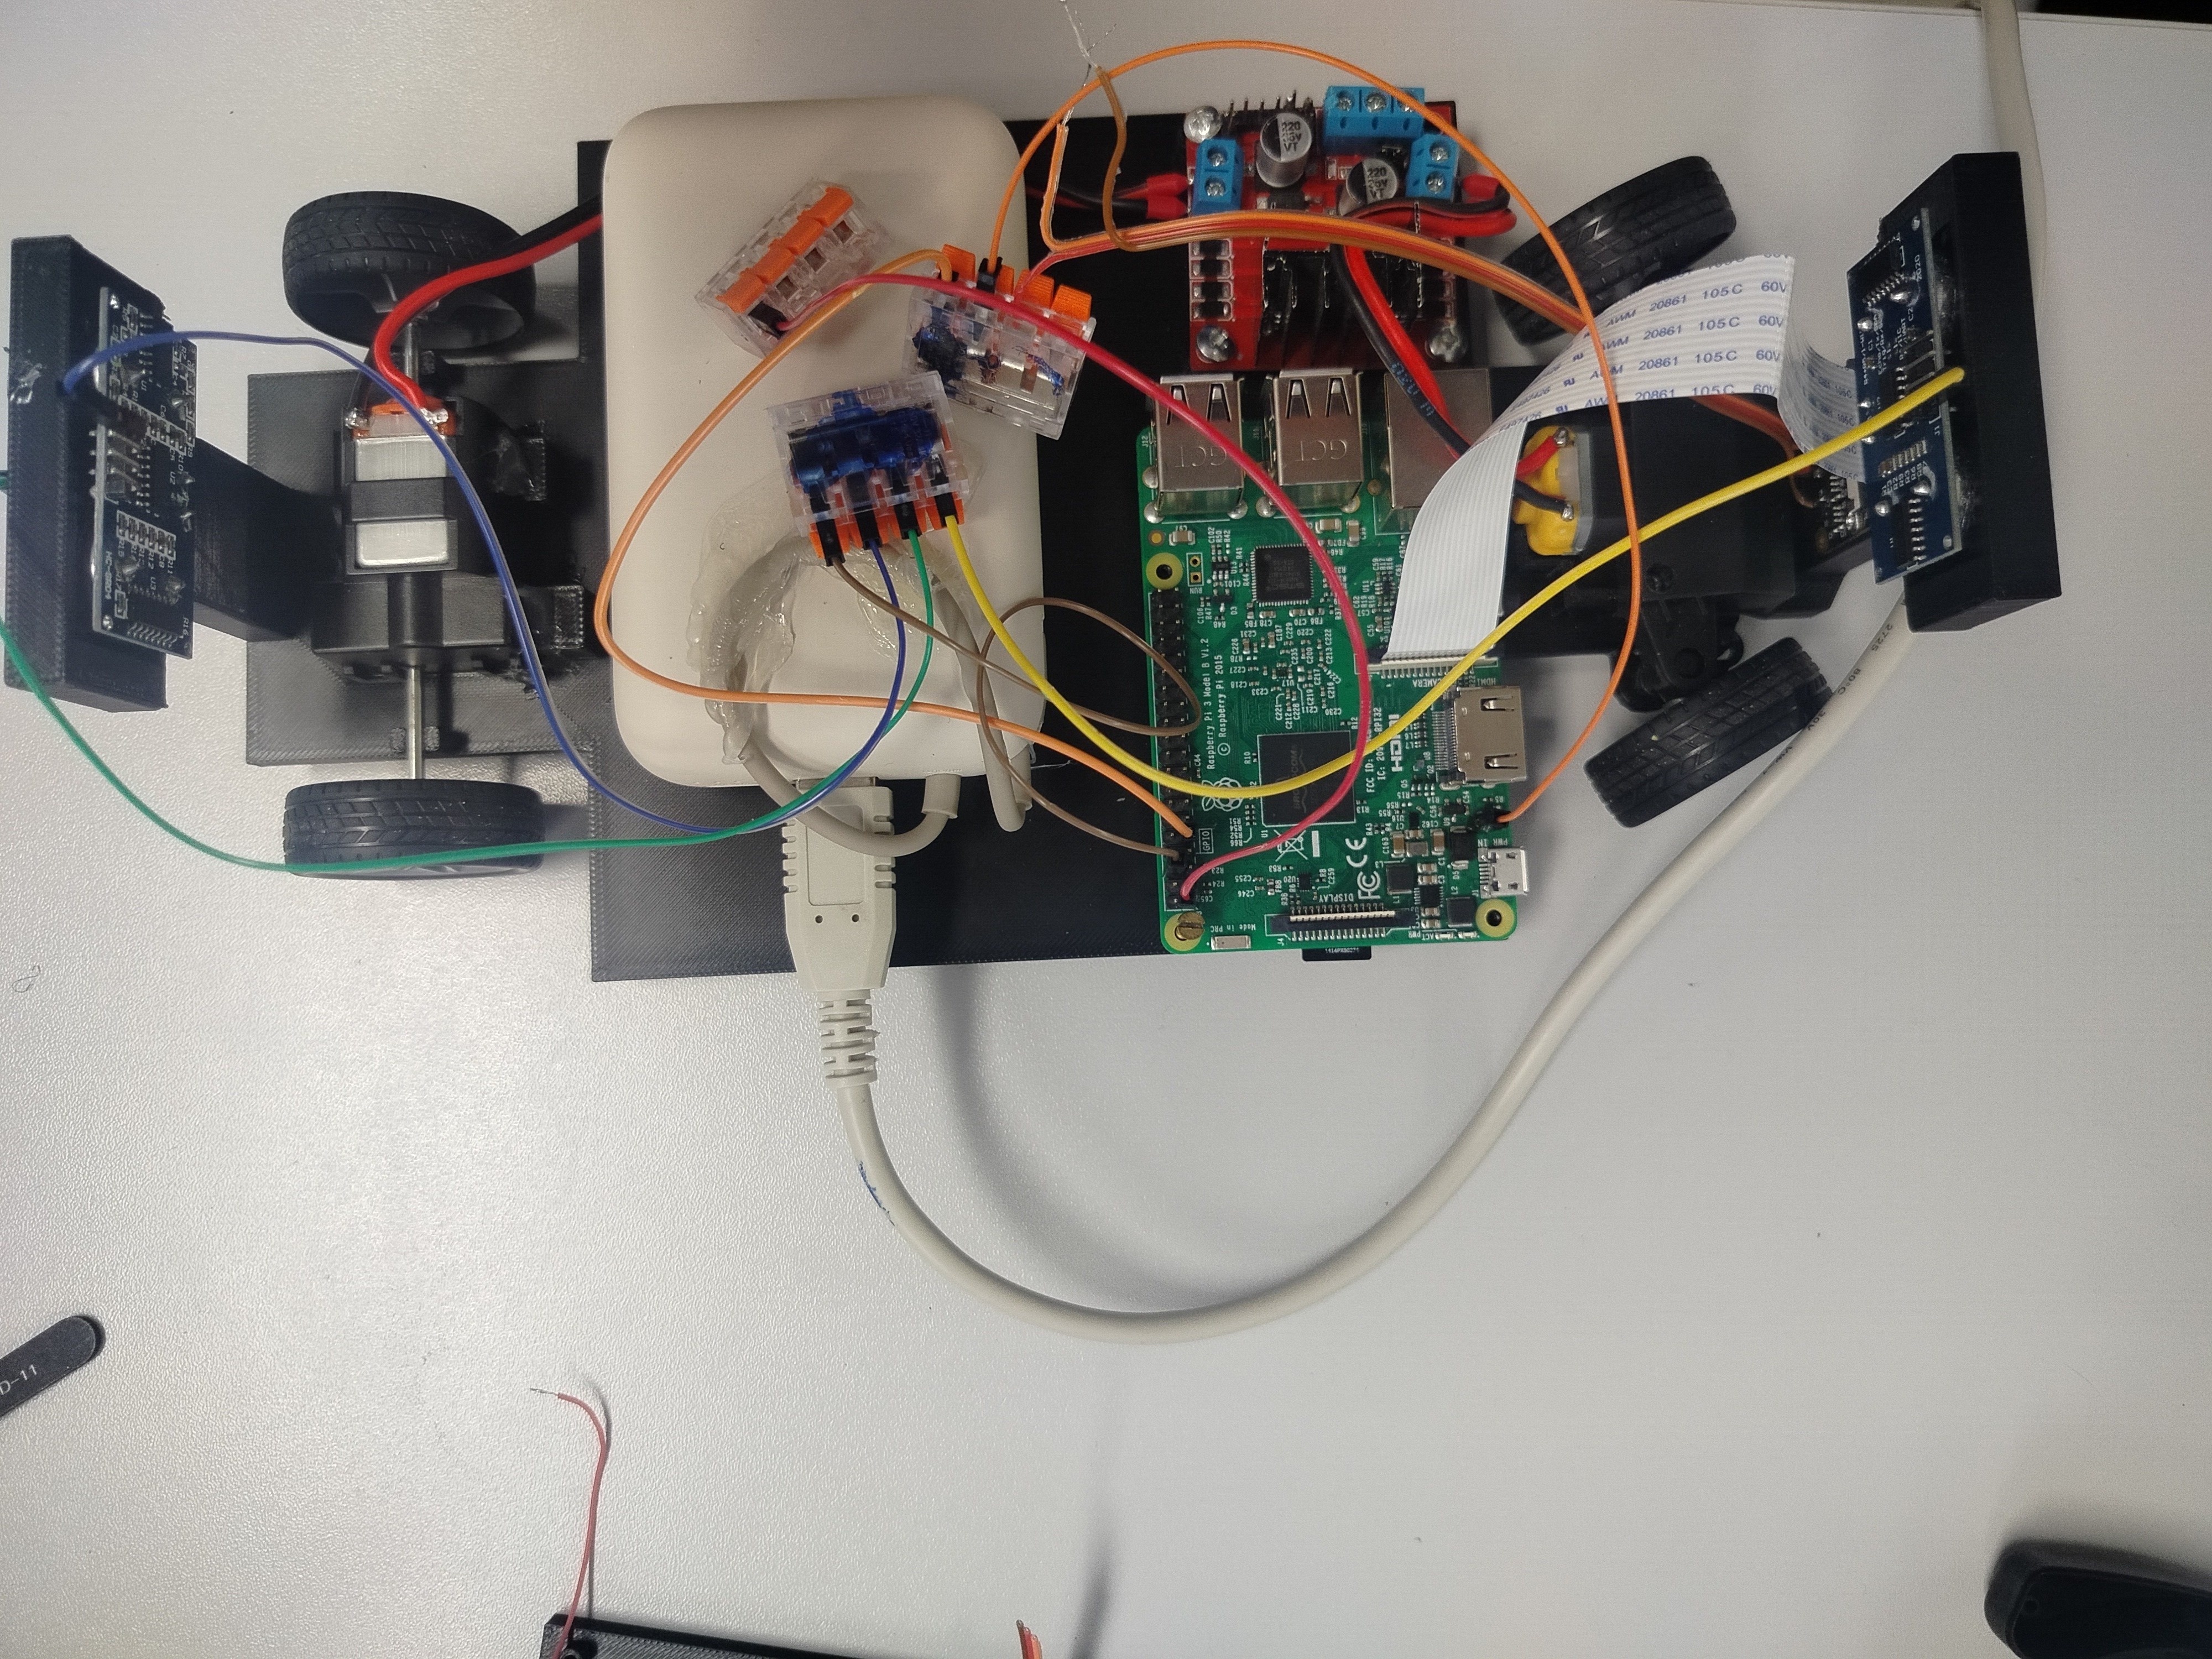
The robot navigates the competition track and avoids obstacles fully autonomously using computer vision, distance sensing, and custom control software. It runs on a Raspberry Pi 3 with a regulated 5 V power system, ultrasonic distance sensors, IR reflectance sensors, a CSI camera, and an L298N motor driver for drivetrain and steering.
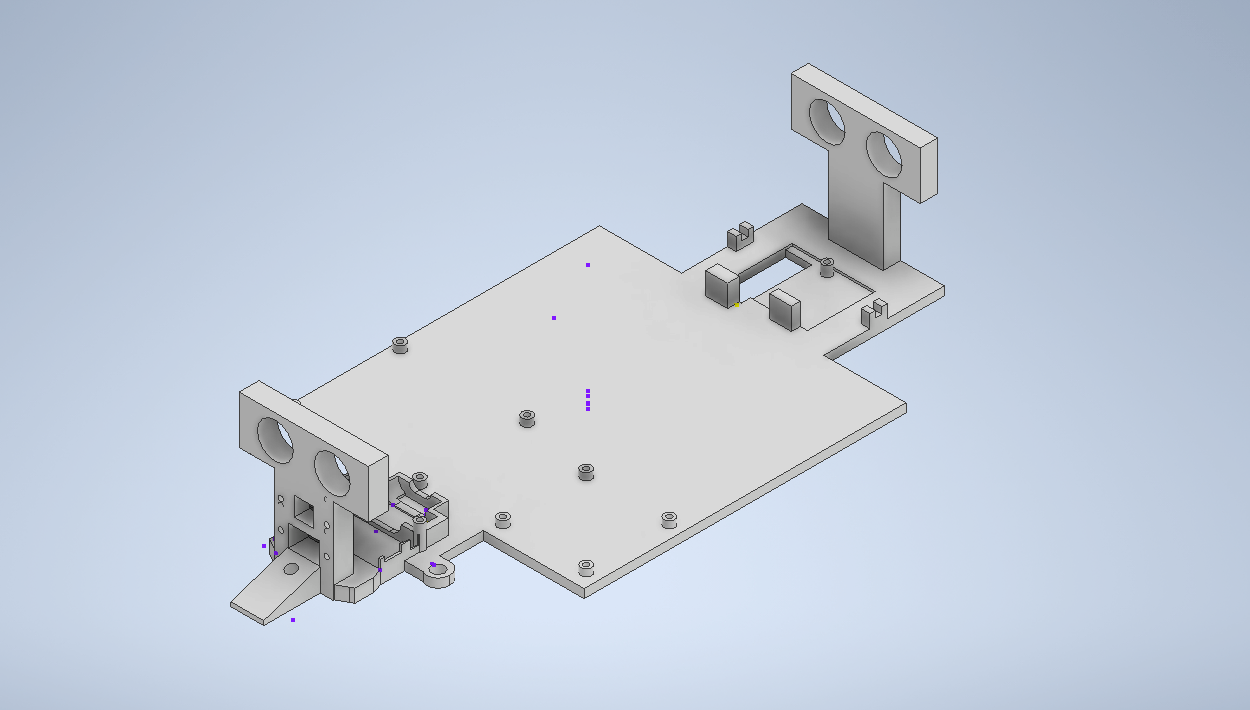
The Python control software combines camera-based color detection, distance sensing, race-state logic, PID utilities, and modular hardware drivers. The engineering is split into dedicated repositories — hardware (KiCad schematics and wiring), software (robot runtime, calibration, and deployment), and mechanical (3D-printable design files).