Projects
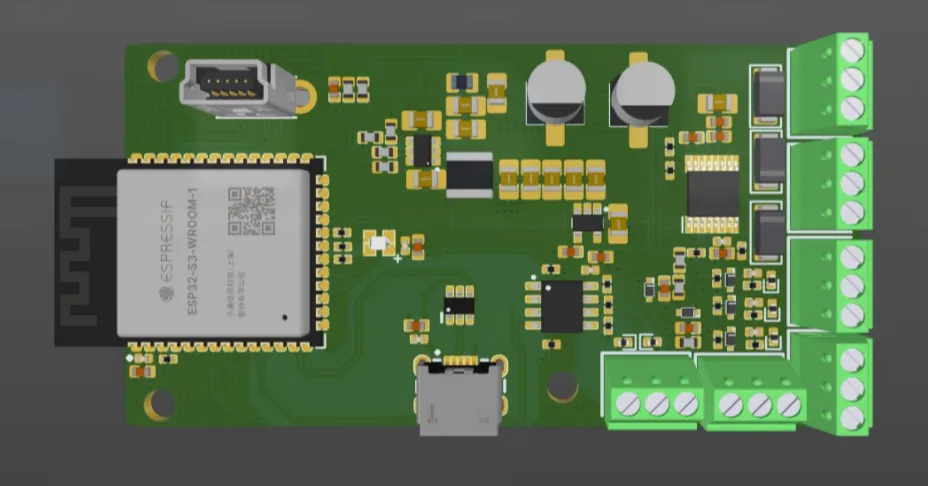
DC Motor Position Control System
A real-time closed-loop DC motor position controller — custom ESP32-S3 PCB, PID firmware, LabVIEW HMI, and a Python fuzzy-vs-PID simulation.
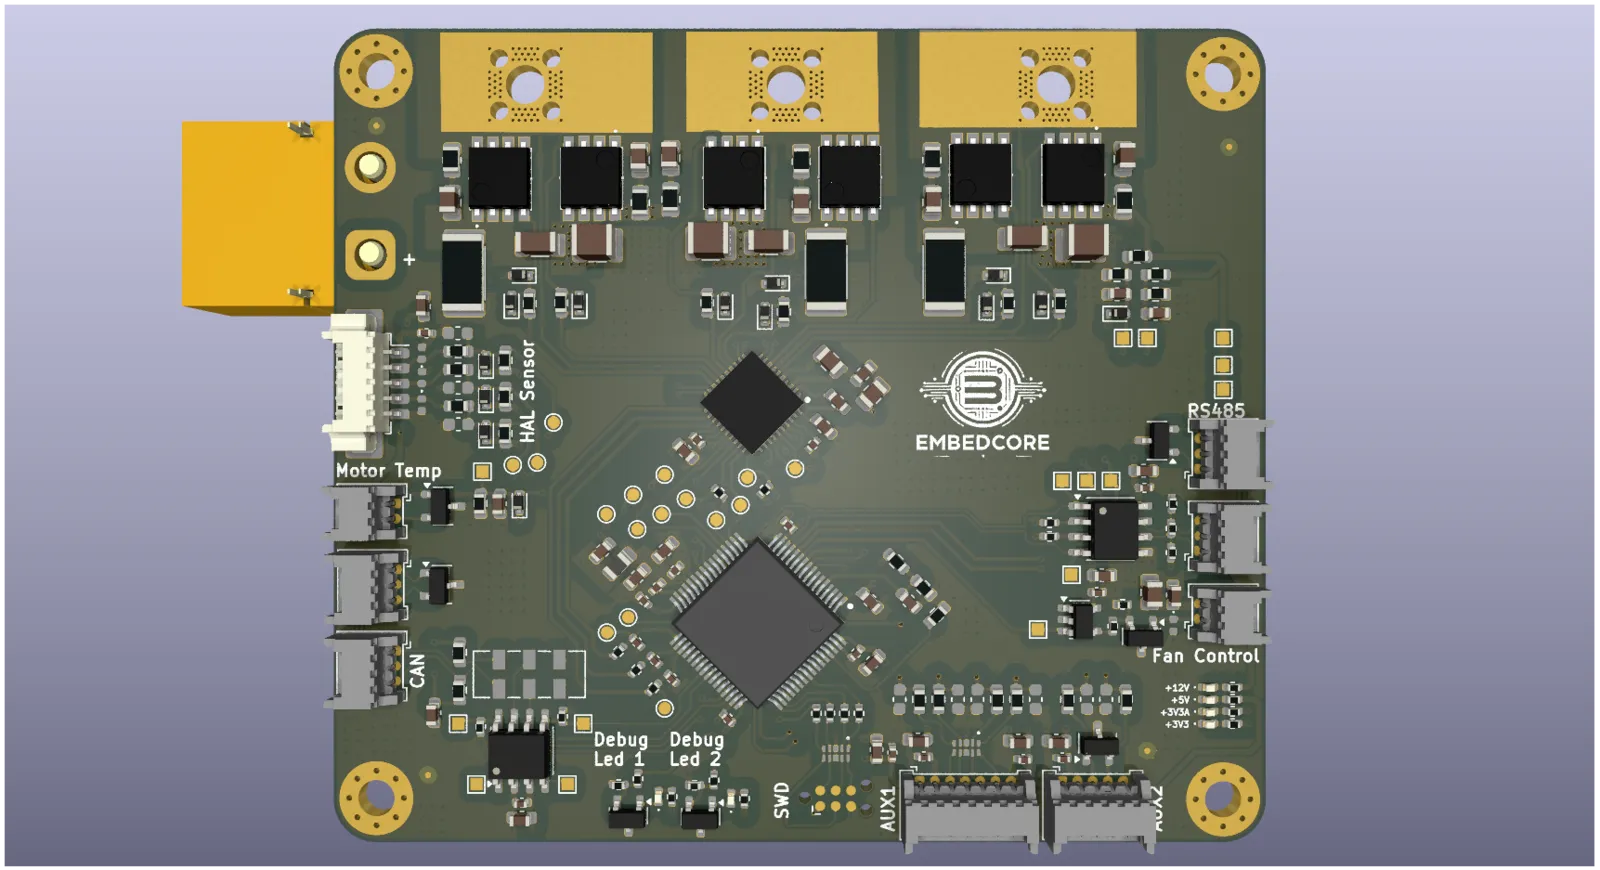
EmbedCore BLDC Motor Controller
A 100 A brushless motor controller on a 67 × 76.5 mm HDI board, built for autonomous mobile robot wheel actuators.
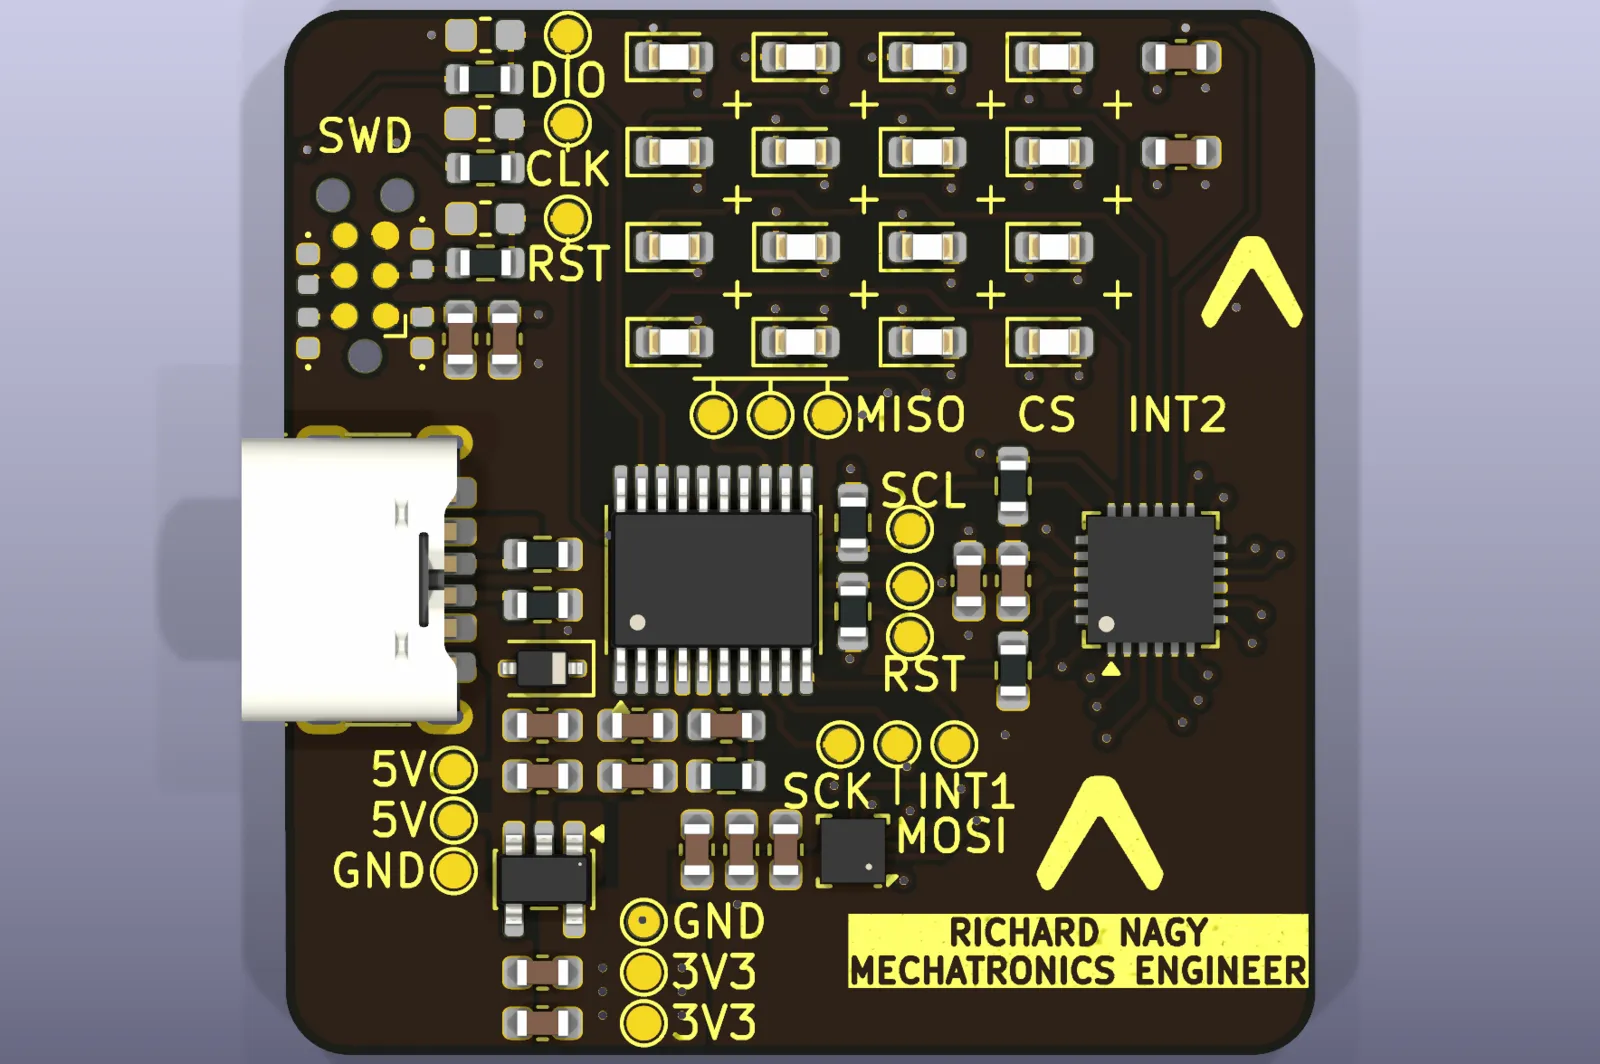
Embedded Business Card
A business-card-format PCB that lights up and reacts to motion — STM32C011, a 4×4 LED grid and an accelerometer, powered from USB-C.
LCSC BOM Verification Tool
A Python CLI that verifies Bill-of-Materials components against live LCSC data.
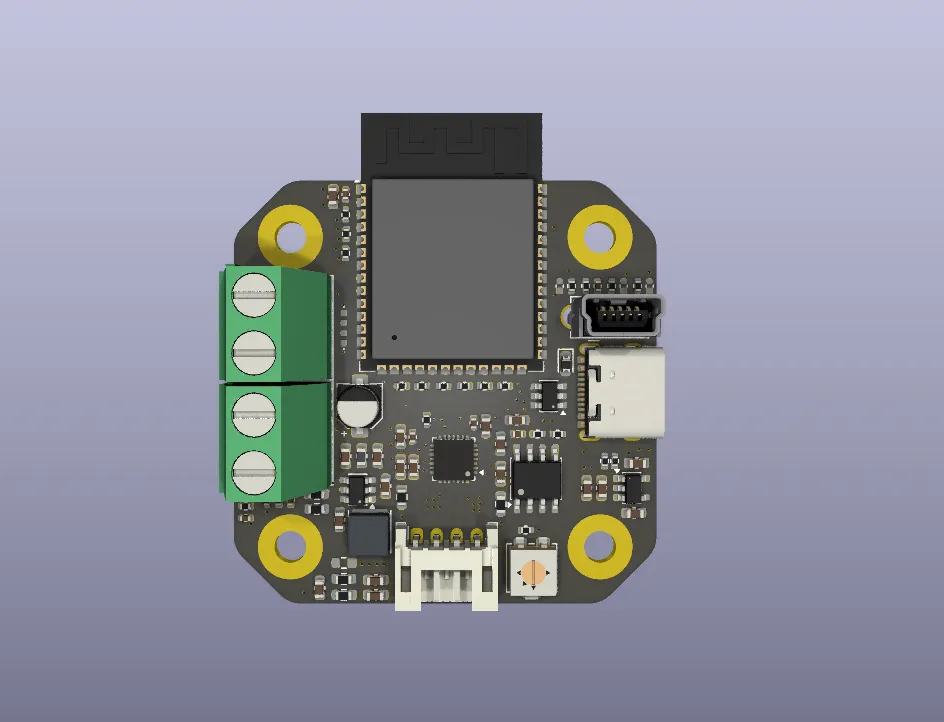
EmbedCore Stepper Motor Controller
A compact ESP32-S3 stepper driver that mounts on the back of a NEMA 17 motor (hardware design, not yet tested).
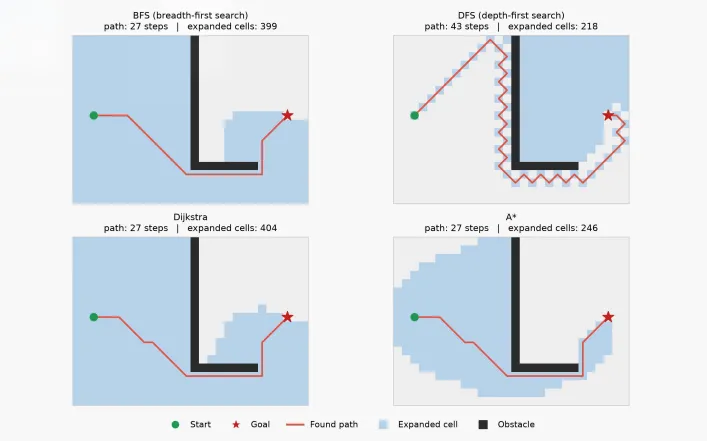
Autonomous Mobile Robot Navigation in ROS 2
My completed final thesis: autonomous path planning for a mobile robot in ROS 2 and Gazebo.
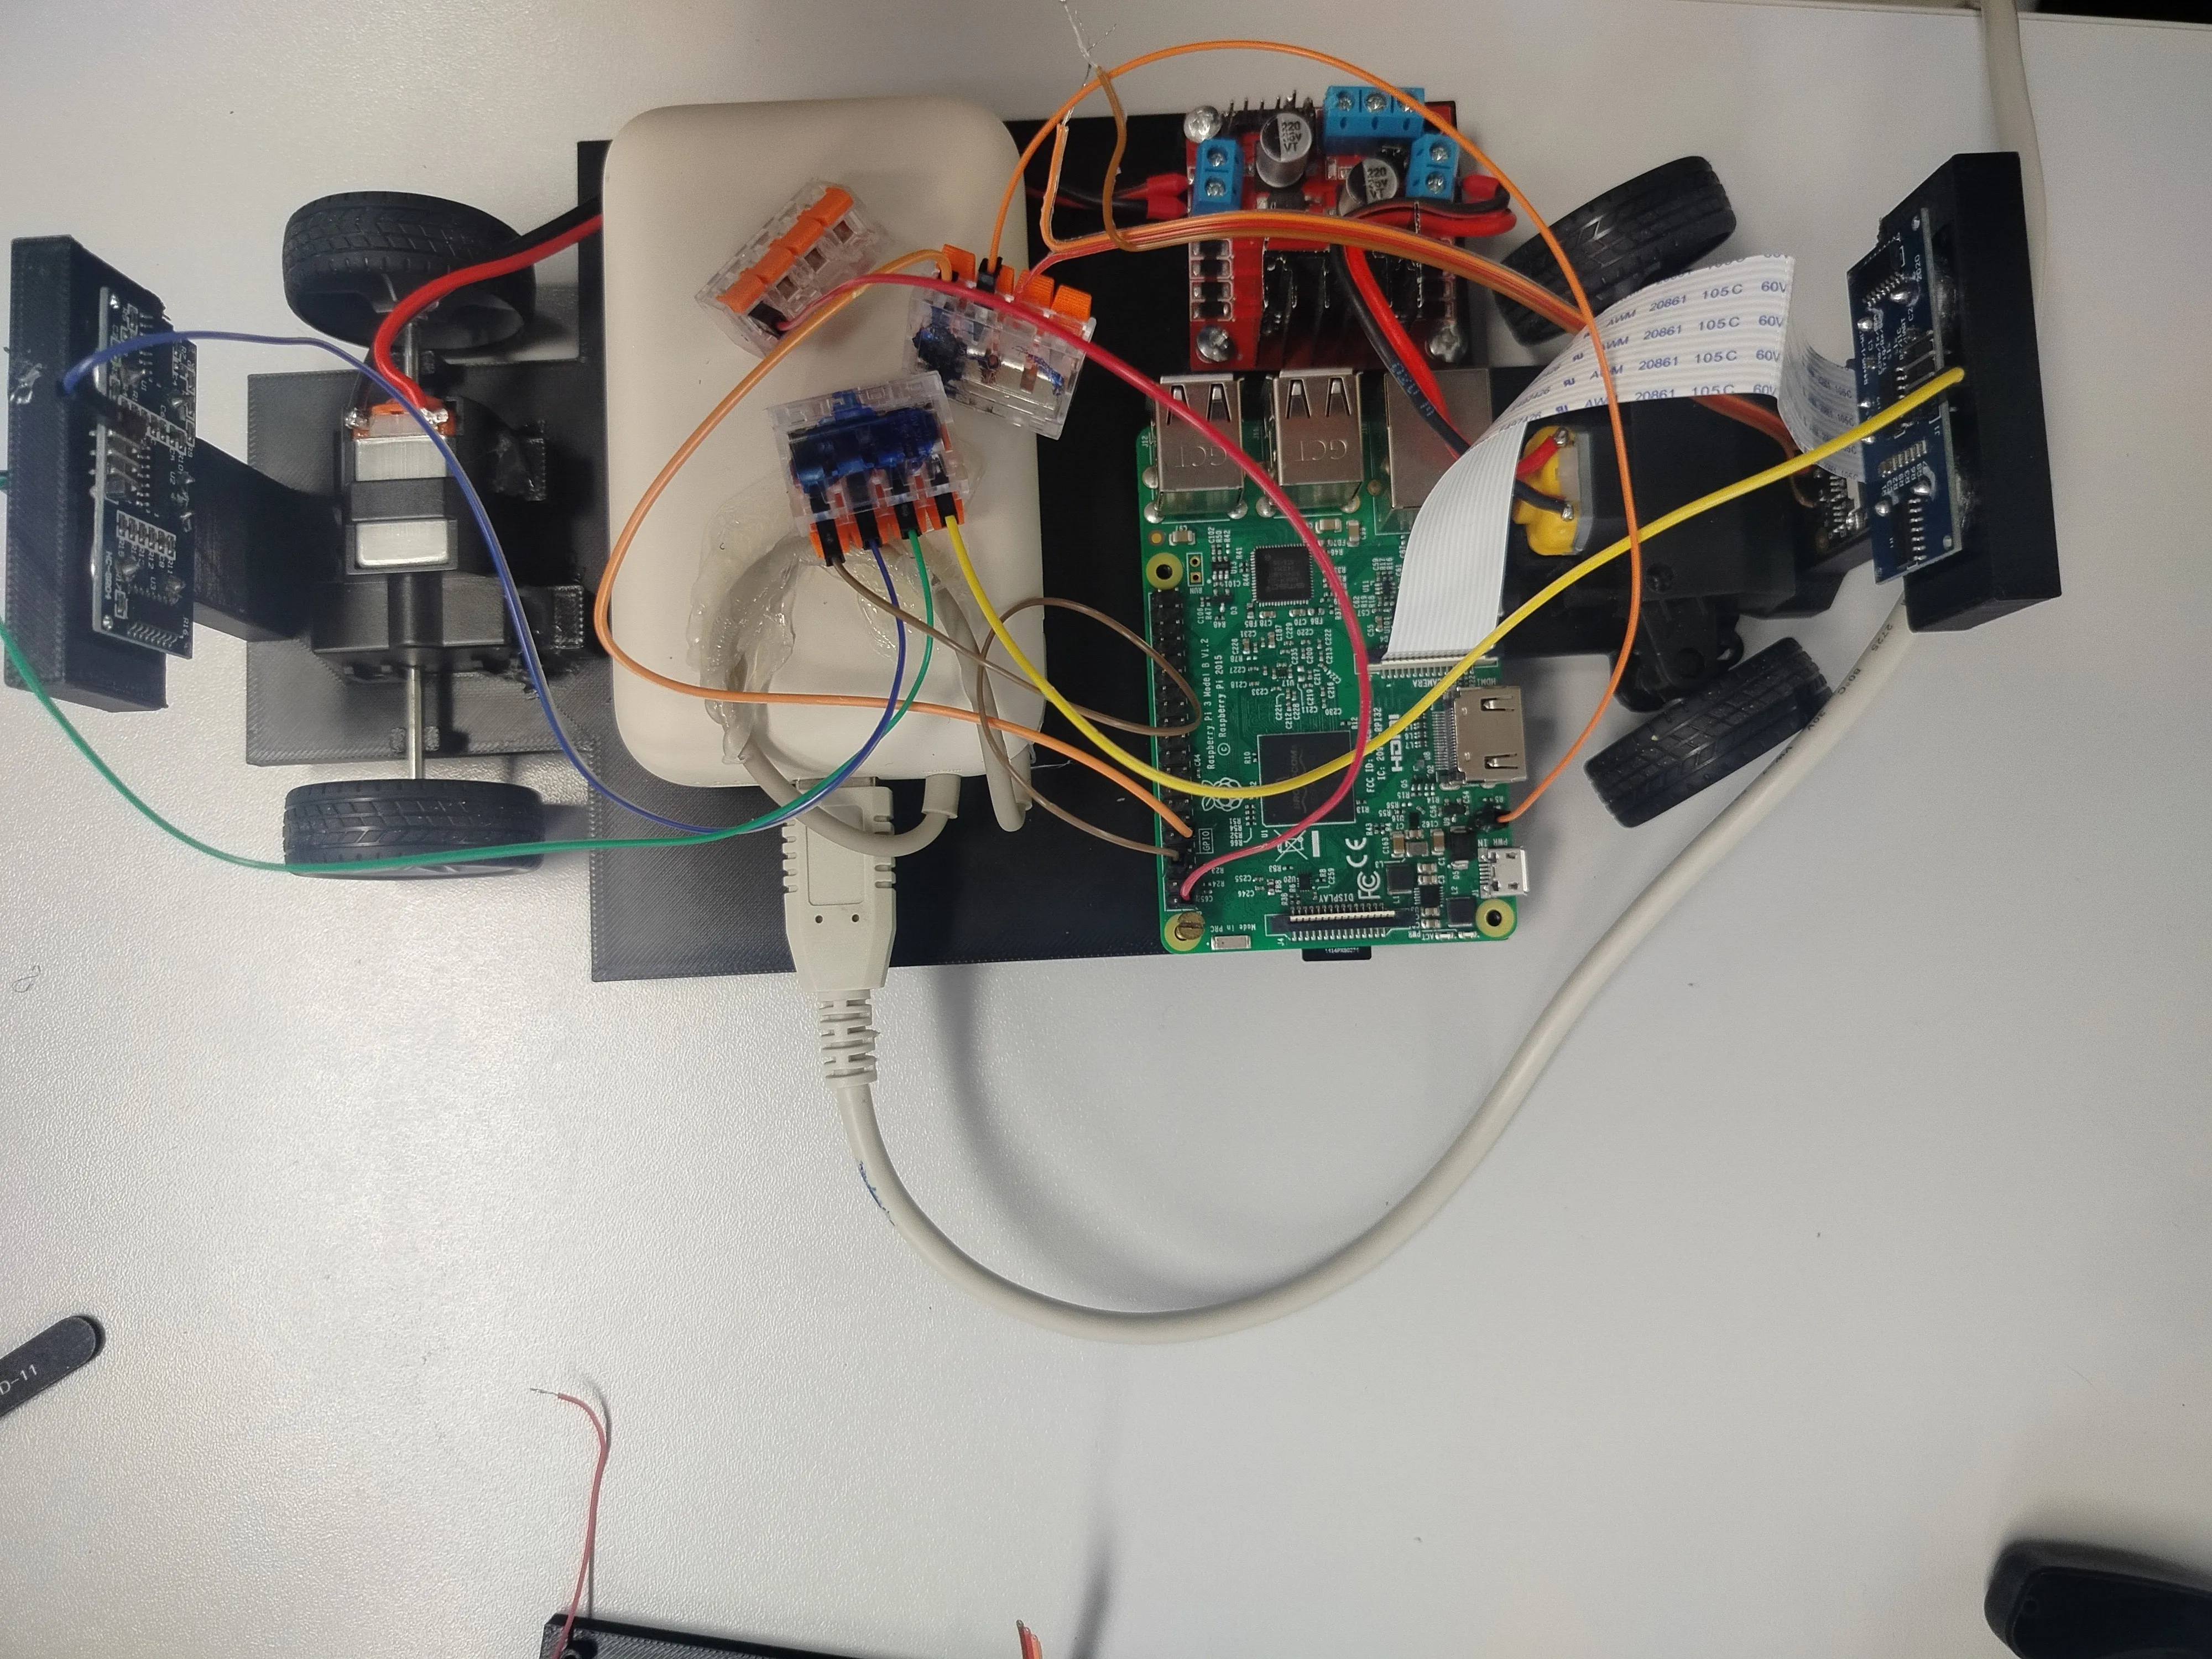
WRO Future Engineers 2026 — Autonomous Vehicle
Project lead for a self-driving robot built for the World Robot Olympiad Future Engineers 2026 competition.
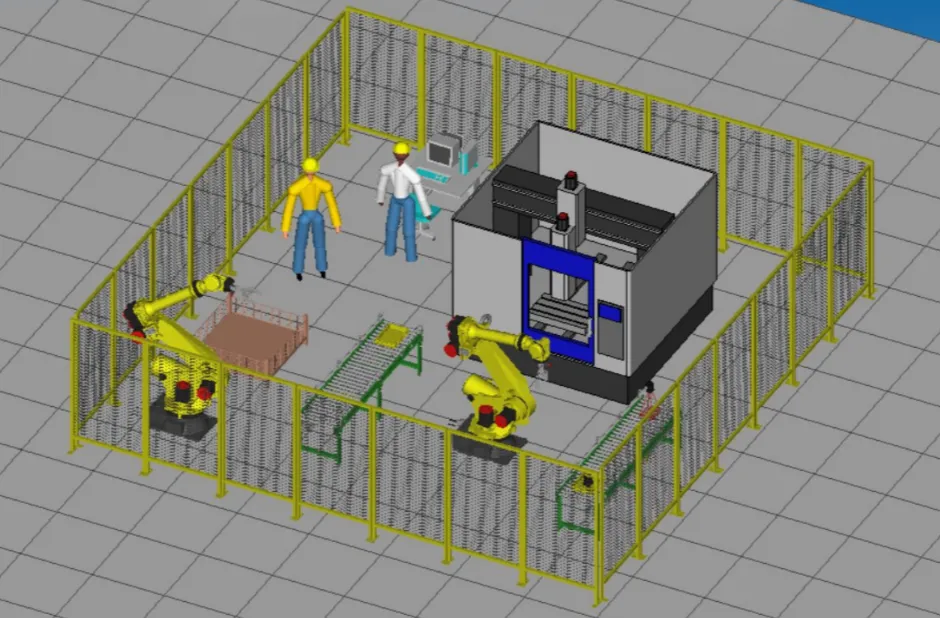
Industrial Robotic CNC Workcell Simulation
A FANUC RoboGuide simulation of a dual-robot CNC tending and palletizing workcell.
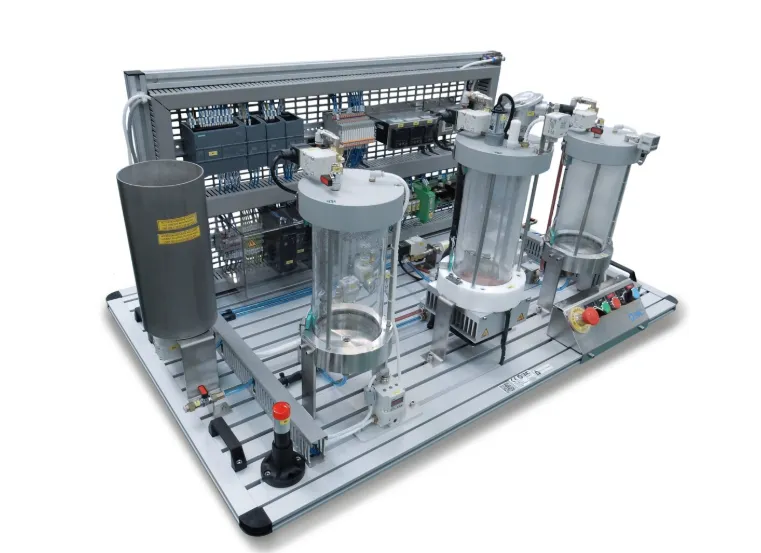
Industrial Apple Juice Processing System
A fully automated three-tank apple-juice production line, controlled by a Siemens S7-1200 PLC.
CartPole Fuzzy Control System
A Mamdani fuzzy-logic controller that balances the classic CartPole with continuous force control.