Control & Simulation
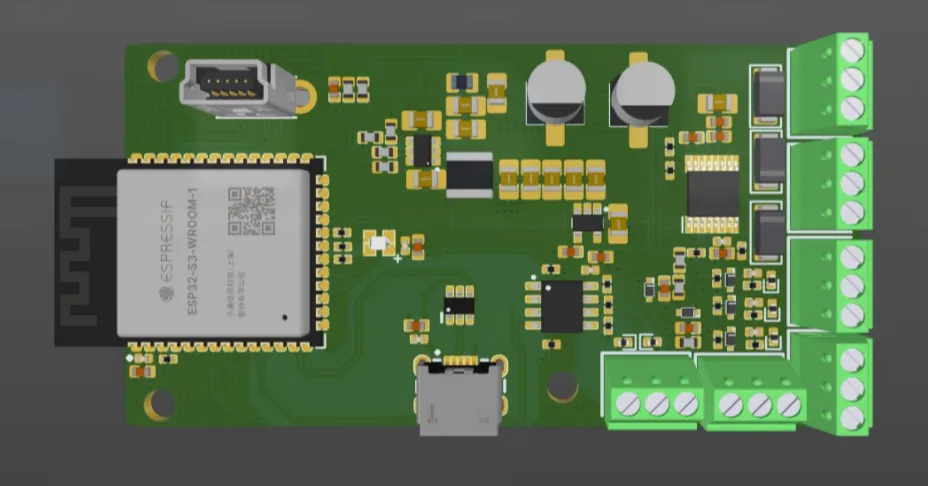
DC Motor Position Control System
A real-time closed-loop DC motor position controller — custom ESP32-S3 PCB, PID firmware, LabVIEW HMI, and a Python fuzzy-vs-PID simulation.
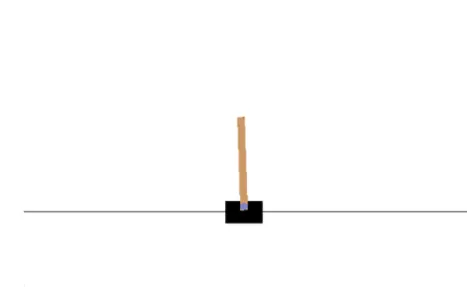
CartPole Fuzzy Control System
A Mamdani fuzzy-logic controller that balances the classic CartPole with continuous force control.