Robotics
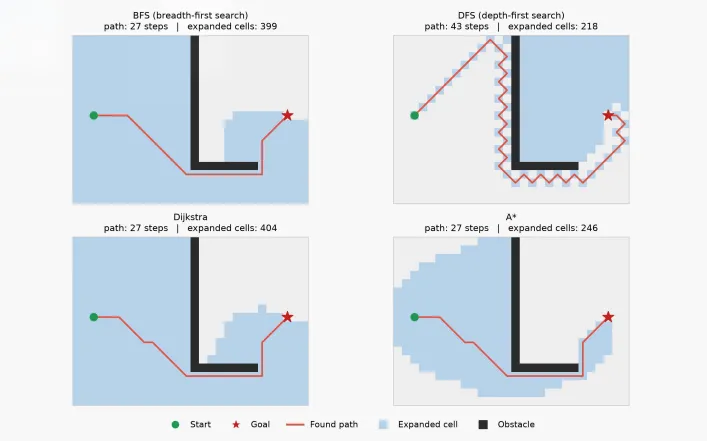
Autonomous Mobile Robot Navigation in ROS 2
My completed final thesis: autonomous path planning for a mobile robot in ROS 2 and Gazebo.
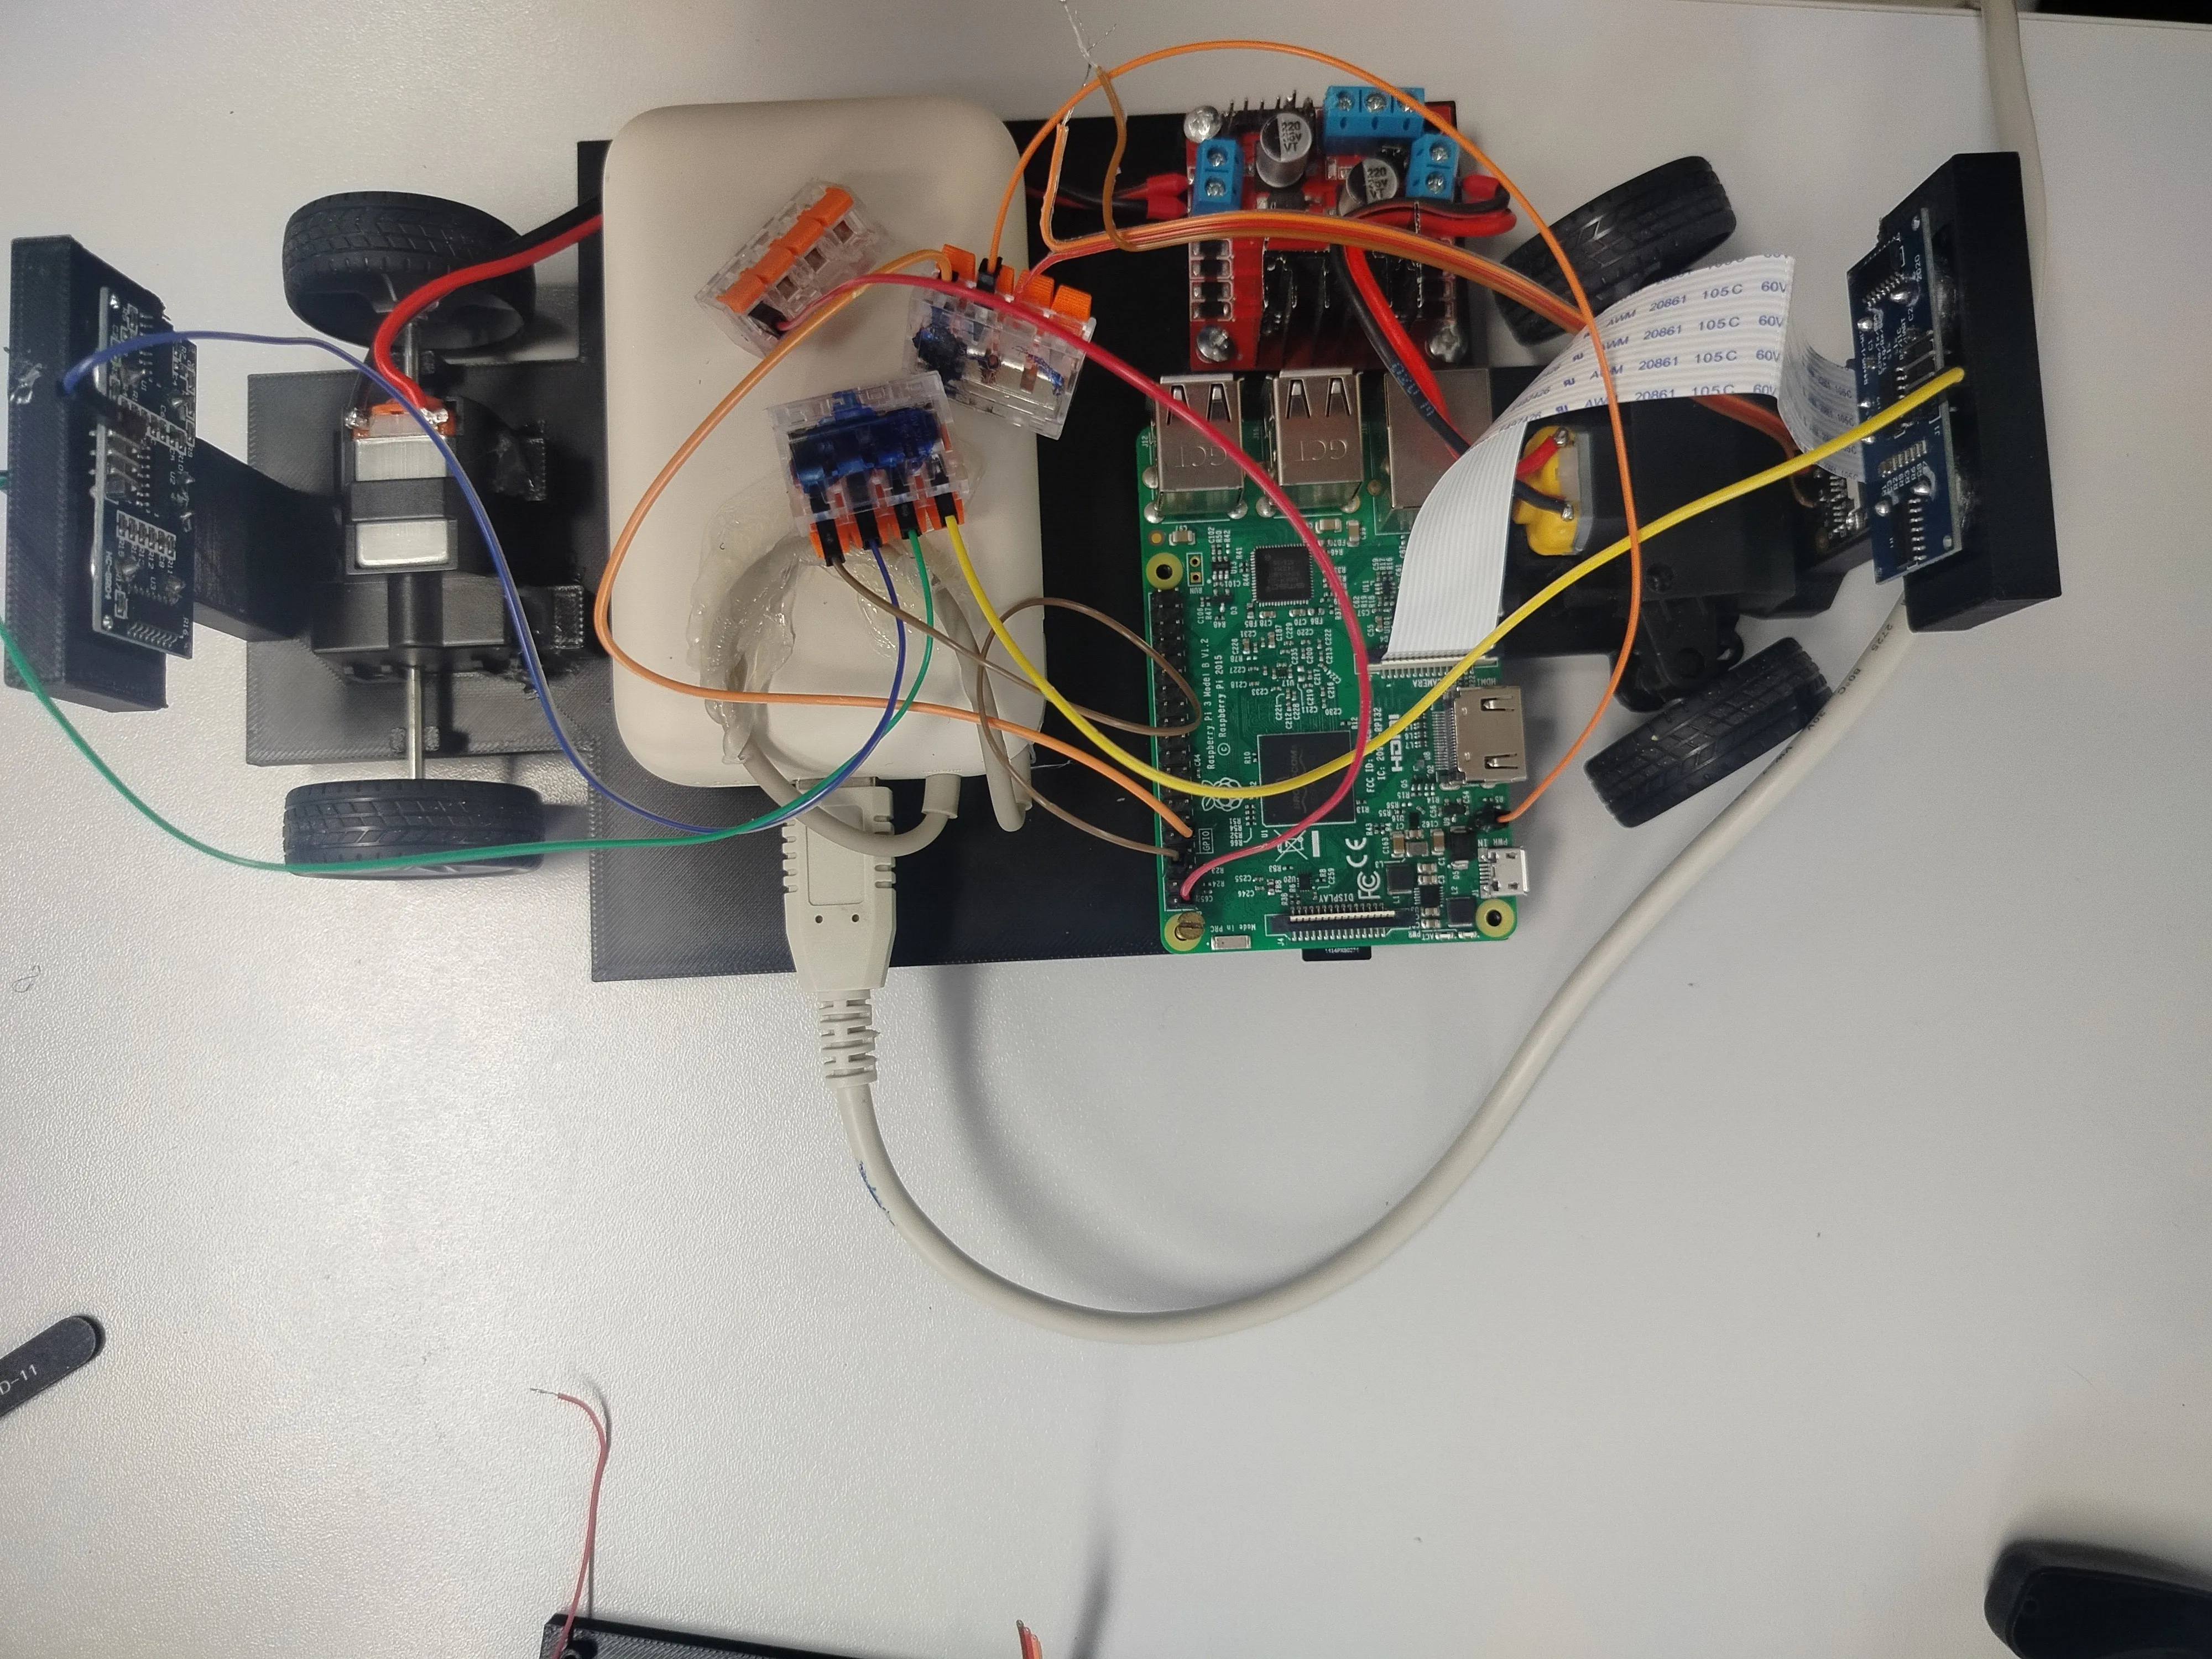
WRO Future Engineers 2026 — Autonomous Vehicle
Project lead for a self-driving robot built for the World Robot Olympiad Future Engineers 2026 competition.
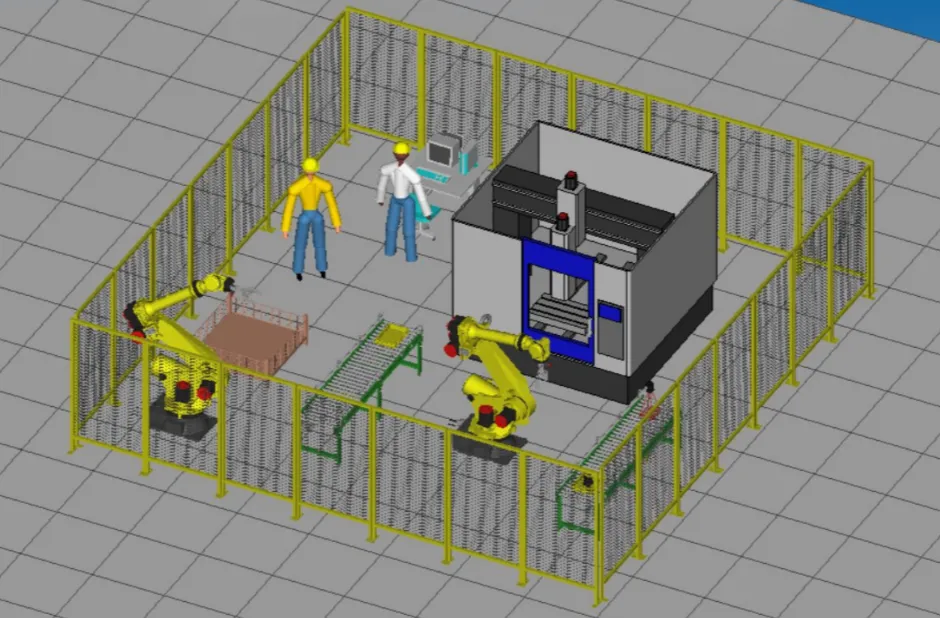
Industrial Robotic CNC Workcell Simulation
A FANUC RoboGuide simulation of a dual-robot CNC tending and palletizing workcell.